
| Home | Products | Networked Robots | Blog | Software | Applications | Contact | View Cart |
I2C Based Pan and Tilt and Ultrasonic Sensor
A great way to get a handle on I2C is to use IONOTRONICS devices to setup an I2C based Pan and Tilt with Ultrasonic Sensor. We developed a free Java Graphical User Interface to manipulate the Pan and Tilt system as well as the I2C ultrasonic sensor. A schematic of the system is shown below. The IONOTRONICS devices are shown in the Table below the schematic. Note that to convert a PWM based Servo Motor to an I2C Slave we need either the MK-24316 or MK-44149. Both use a PIC16F1825. IONOTRONICS pre-programs the PIC16F1825 with the firmware to convert a PWM Servo Motor to an I2C Slave. The Firmware is availabe for download (Hex). See here.
By using the PIC16F1825 as an I2C PWM slave ( or I2C Ultrasonics Slave), Robotic Systems can be built that scale. For example 5 ultrasonic I2C devices can be added to a Rover to measure distance to all sides and more. A system of multiple PWM I2C Slaves can be used to manipulate multiple ARMS as well as control, for example, a Sabertooth Motor Controller. See the Rover and Arm Blueprints. Also unlike single microcontroller solutions, there is no limit to the number of PWM devices and Ultrasonic devices that can be added except by the number of I2C addresses available. Finally, the control software is robust and elegant since all processing is perfromed in a scalable distributed number of PIC16F1825 totally offloading the microcontroller and simplifying the soiftware.
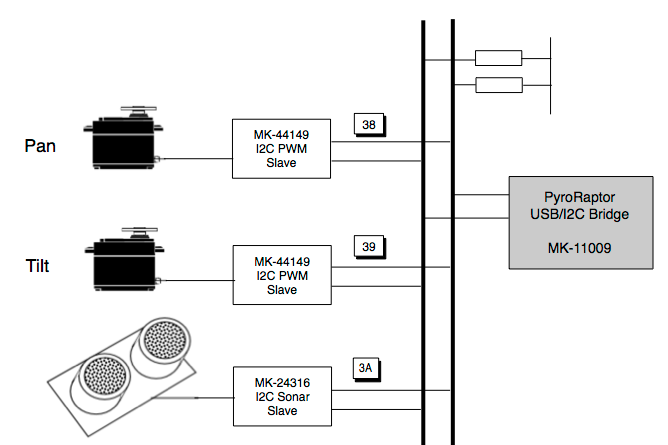
Schematic of I2C based Pan and Tilt and Ultrasonic Sensor
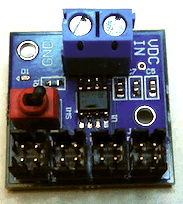
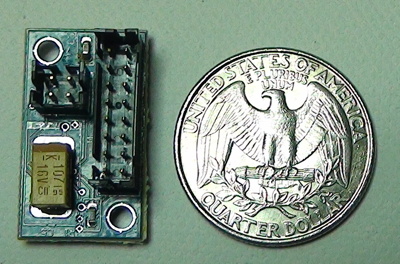
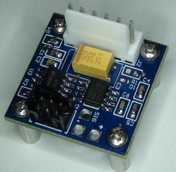
| MK-77988 12-6V to 5.0 LDO | MK-28988 PIC16F1825 I2C PWM | MK-44149 PIC16F1825 I2C PWM with Current Monitoring | MK-11009 USB/I2C Bridge |
 |
 |
 |
 |
Table Showing IONOTRONICS devices to setup I2C based Pan and Tilt and Ultrasonic Sensor.
For both the MK-24316 or MK-44149 the I2C address can be easily changed using the Java Pyroraptor Graphical Interface. See the  Video.The new I2C address is stored in the PIC EEPROM.
I2C Pan and Tilt with Ultrasonic Sensor
The Figures below show the setup for the I2C Pan and Tilt and Ultrasonic. For a Video on using the Pot/meter to position the Pan and Tilt see video. For a Video showing scanning with the Ultrasonic Sensor using the Java Payroraptor Graphical Interface Tab see. For detailed description of the Pan and Tilt with Ultrasonic see this video.

I2C Based Pan and Tilt with Ultrasonic. The yellow parts are 3D printed with the design available from IONOTRONICS
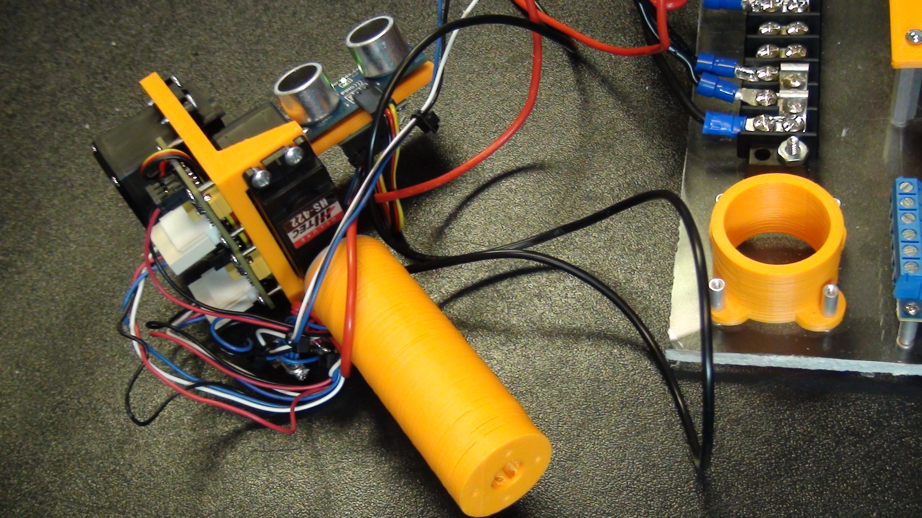
Pan and Tilt removed from base for trasnport in a case.
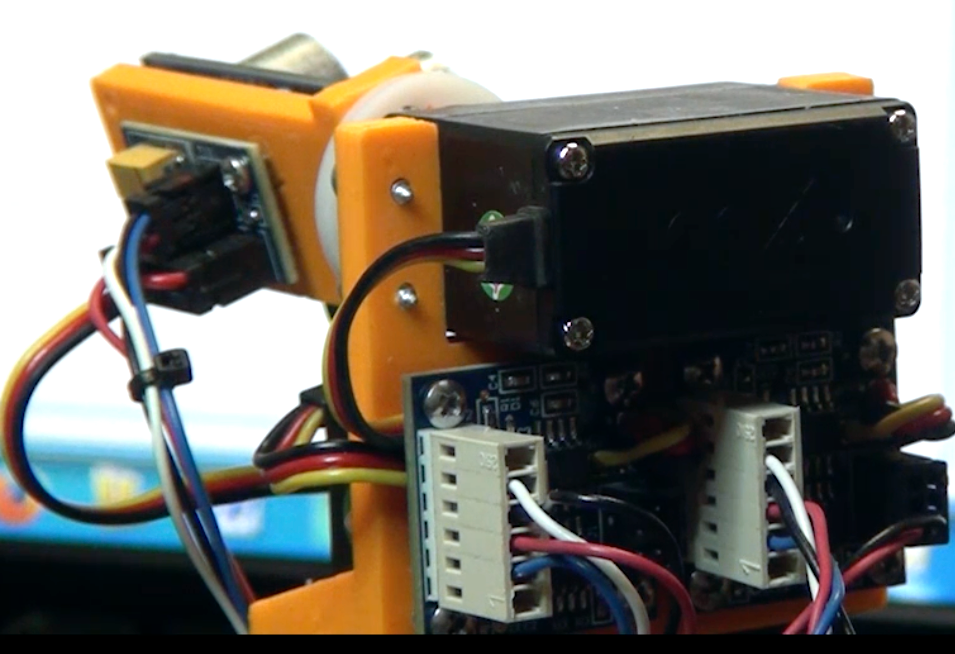
Pan and Tilt with Ultrasonic Sensor showing the two MK-44149s for I2C PWM Control and a MK-24316 to convert the Ultrasonic Sensor to an I21C Slave
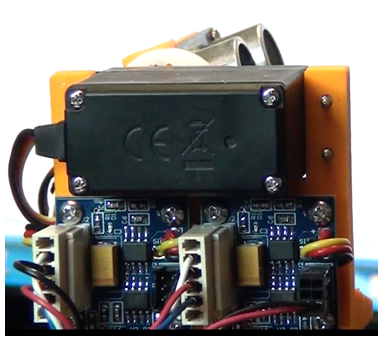
Pan and Tilt showing the two MK-44149s for I2C PWM Control
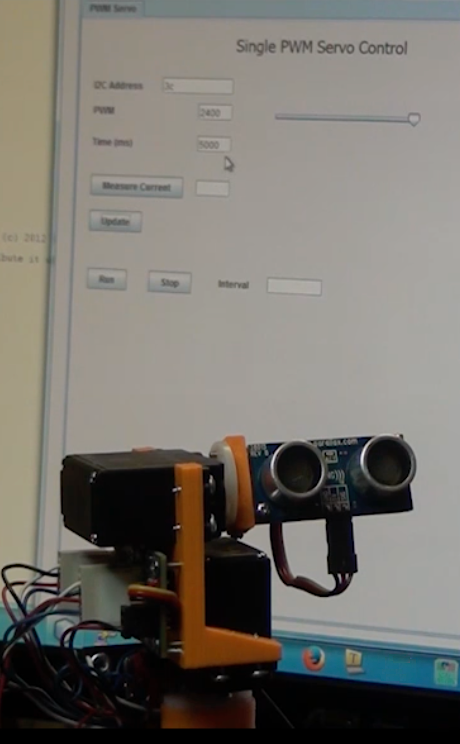
Java Pyroraptor Graphical User Interface showing Tab for individual I2C PWM Servo Control (setting PWM e.g. 800-2400 usec and Time in ms as well as I2C Address).

Java Pyroraptor Graphical Interface with Ultrasonic Tab. Note Java Bean Meter that shows measured distance from I2C Ultrasonic Sensor to Object. Note that measurments taken at 300ms intervals.
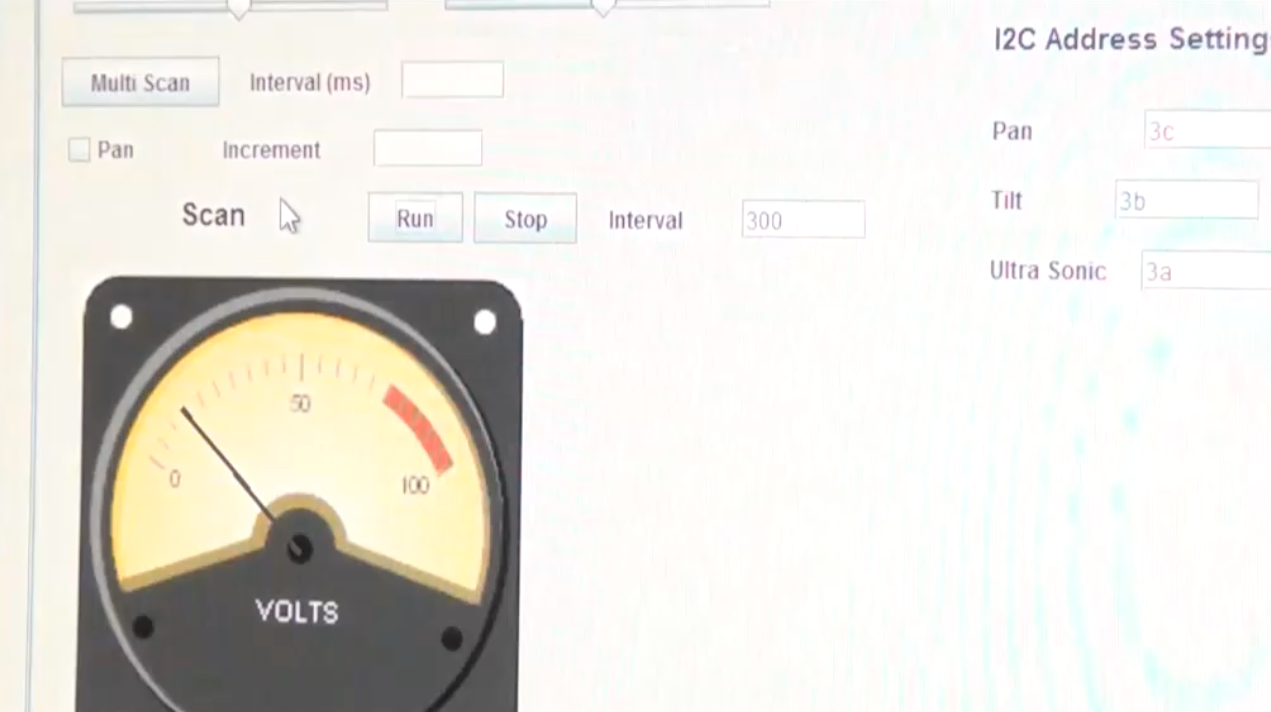
Java Pyroraptor Graphical Interface with Ultrasonic Tab. Java Been meter shows close distance measurement as object in close proximity to Ultrasonic Sensor.

The Pyroraptor Java Graphical Interface allows the pan and tilt to be controlled using the Potentiometers on the MK-72110.
