
| Home | Products | Networked Robots | Blog | Software | Applications | Contact | View Cart |
Remote Robot Command/Control Program (RRCP)
Video Links
The Remote Robot Command Program (RRCP) is an Open Source Firmware developed by IONOTRONICS for embedded processors. Currently a 32 bit PIC ( PIC32MX360F512) and an enhanced 8 bit PIC (PIC16F1947) are supported. The Firmware is written in C and is supplied pre-programmed into the PIC Microcontrollers. This includes for both Embedded Processor Adaptor Boards MK-33856 and the MK-28988 that mate to the Eoraptor Robotics Platform.
The RRCP allows for a remote program (through Wireless TCP/IP) or a program running on a local machine, through an RS-232 connection, to control Robots or Industrial Applications.
Documentation
The RRCP User Guides provide the syntax for each command. RRCP is fully documented. Applications can be written in Java , Python or other high level languages to send commands to the pre-programmed 32 bit or 8 bit PIC microcontrollers to control a vast set of capability in a Robot. No programming is necessary for the embedded micocontroller that controls the Robot. In fact, you can use Telnet or for direct RS-232 interface TeraTerm on Windows or mincom on Linux to send commands.
| Embedded Processor | Chip | Adaptor Board | Word | |
|---|---|---|---|---|
| PIC32MX360F512 | 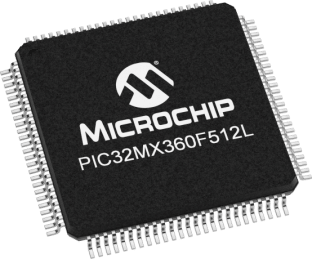 |
MK-33856 |  |
Word |
| PIC16F1947 | 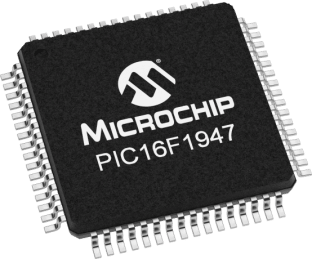 |
MK-28988 | |
Word |
Example List of Commands
| Number | Command |
| 1 | Identification and Test |
| 2 | I2C Multiple Servo Control |
| 3 | SSC32 Servo Controller |
| 4 | I2C LCD Commands |
| 5 | Saber Servo Controller Through I2C PIC16F1825's |
| 6 | Servo Control via I2C PIC16F1825 |
| 7 | I2C Ultrasonic |
| 8 | Gyroscopes |
| 9 | LED GPIO A0-A3 |
| 10 | RGB LED |
| 11 | Read GPIO Port A 8 Bits |
| 12 | Read GPIO Port B 8 Bits |
| 13 | Read GPIO Port D 8 Bits |
| 14 | Meter Command (DAC Value Set) |
| 15 | Set ADC Channel |
| 16 | Read ADC 8 bit Value (Channel Set by adh Command Default 0) |
| 17 | Read 4xADC Values (4 Channels 8 bits Each) |
| 18 | Sonar Continuous Read and Output to Meter |
| 19 | Morse Code Send Text |
| 20 | Morse Code Timing Set |
| 21 | Verbose On or Off |
| 22 | SPI |
| 23 | PIN |
| 24 | Analog Accelerometer |
| 25 | I2C 3-Axis Accelerometer |
| 26 | Camera Take and Upload Picture (PIC32) |
RRCP In Action
Here are a few YouTube videos that demonstrate RRCP in action. That is, a Java Application is sending commands to the embedded microcontroller running RRCP that controls the Robot. The Java application also reads sensor data through RRCP and provide visualization and/or autonomous operation using sensors ( gyro, accelerometers, ultrasonic ).
Item |
Description | Link |
|---|---|---|
1 |
Rover Wireless TCP/IP Autonomous Obstacle Avoidance Panning Ultrasonic PIC32 RRCP | |
2 |
Cubesat Gyro Navball Demonstration PIC32 RRCP | |
3 |
Stepping Rover Controlled by iPAD Wireless TCP/IP PIC32 RRCP | |
4 |
AL5A Robotic Arm I2C Control Through Java Using Serial RS-232 to PIC32 Running RRCP | |
5 |
I2C BRAT Humanoid Getting Up Autonomous Wireless TCP /IP PIC16F1947 Running RRCP | |
