
| Home | Products | Networked Robots | Blog | Software | Applications | Contact | View Cart |
Datasheet MK-36019
Eororaptor Robotics Platform
|
|
Specifications
|

|
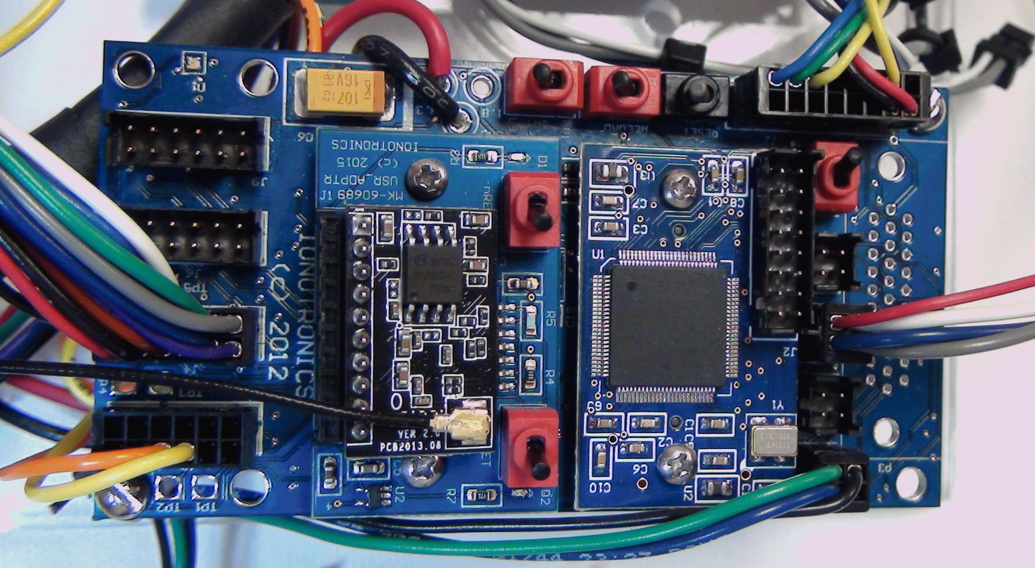
DescriptionThe Eoraptor provides the foundation for SoC's to control Robotic systems. The photo on the right shows the I2C and UART Serial connections as well as the 4 sets of 12 pin Hirose connectors for GPIO from the SoC. A PIC32 SoC Module and a WiFi module have been attached to the Eoraptor. The Eoraptor can provide a Reset to the SoC using a momentary switch. The three configuration switches are key to the Eoraptor. using these switches a Robot can be controlled remotely through Wireless TCP/IP or other Wireless systems. Or, the Robot can be controlled using an RS-2322 interface to the SoC. The SoC can also control devices through the second RS-232 interface. The board contains an integrated ATMEL SPI EEPROM. The SoC can access the Atmel EEPROM or it can be programmed using the 16 pin Hirose connector (using the Pyroraptor and C API for example). External power can be provided as shown. If an on-board ATMEL SPI EEPROM is used,3€4 a 3.3V supply must be used. Four 12 pin Hirose connectors provide for access to GPIO. A 16 pin Hirose connector is used to download firmware or program flash SoCs, as well as the on board SPI EEPROM. Two separate I2C connectors are provided. Status LEDs are provided for the WiFi module.
|
 |
