


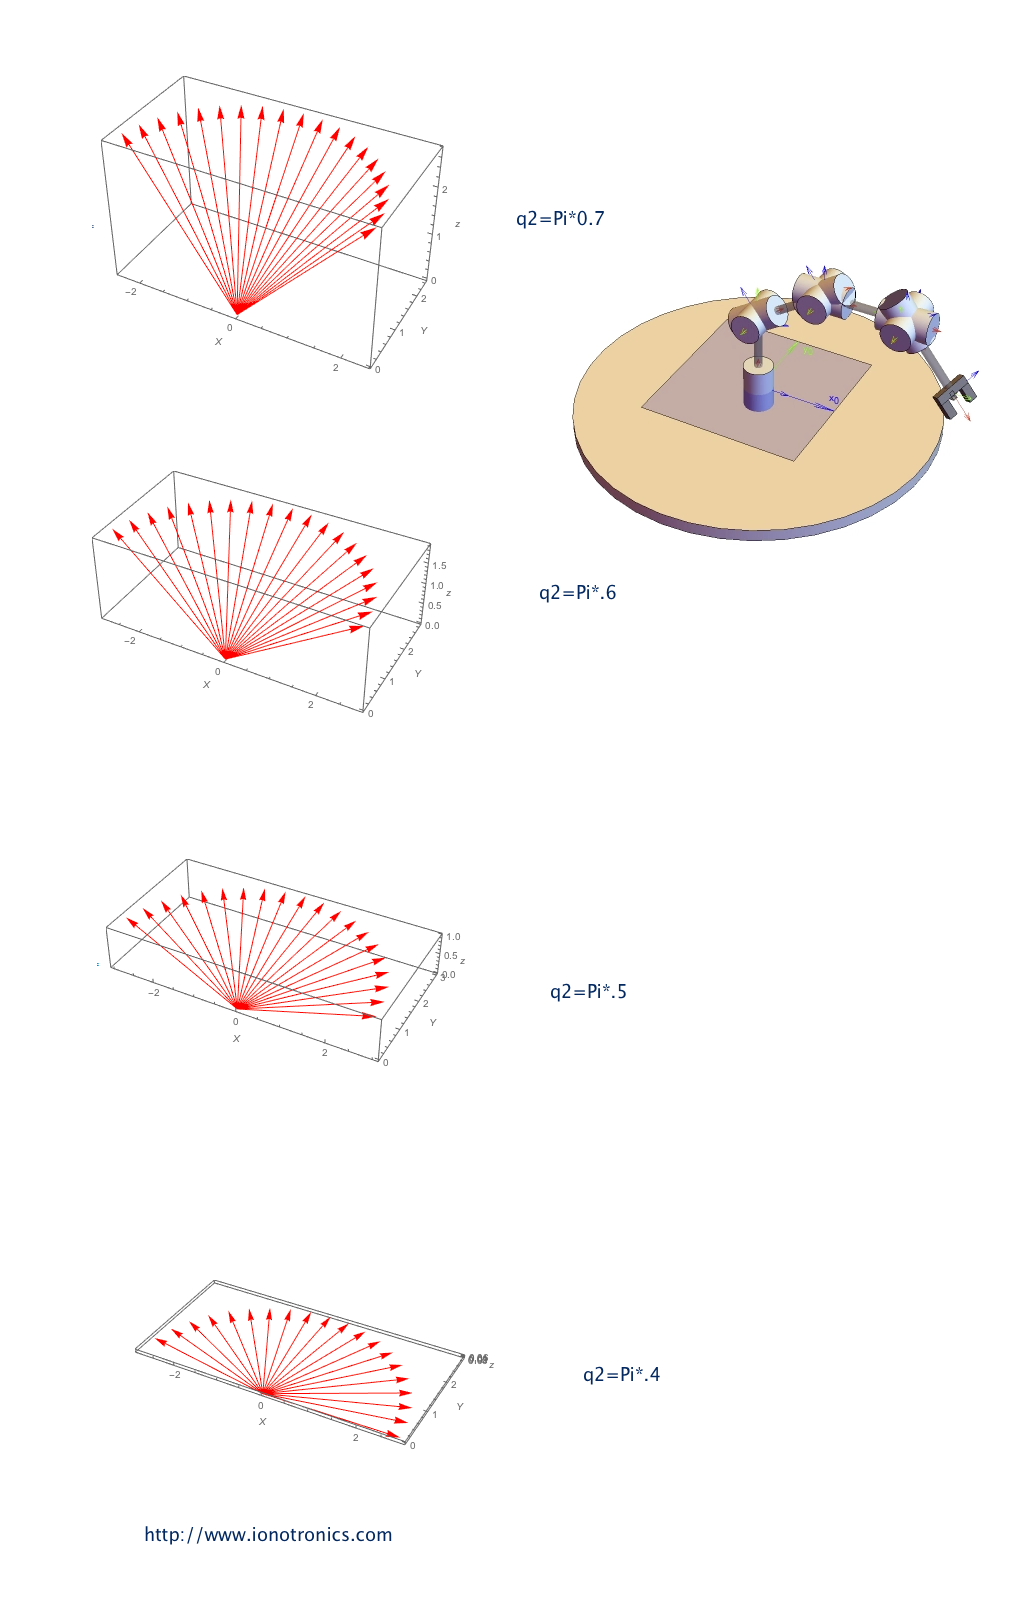
  Forward KinematicsComming Soon.Stay tuned. Preview:The following is a sequence from Mathemnatica® modeling of the IONOTRONICS I2C Based Arm (AL5a based) as the base is rotated. For each sequence the shoulder is rotated with the angle q2 as shown. The tip of the arrow is the gripper.The angle q1 is for the base and is rotated in 20 steps.The Mathematica® Model of the AL5A based Arm is shown ( not to scale). The model is based on the Denavit-Hatenberg (DH) frame parameters for the Arm model using Robotica ( not to scale).
Shopping cart icon credit
 © 2006-2023 IONOTRONICS Corporation All Rights Reserved |